RaLiBEV — Radar & LiDAR BEV Fusion
Co-first author · IEEE TCSVT 2025
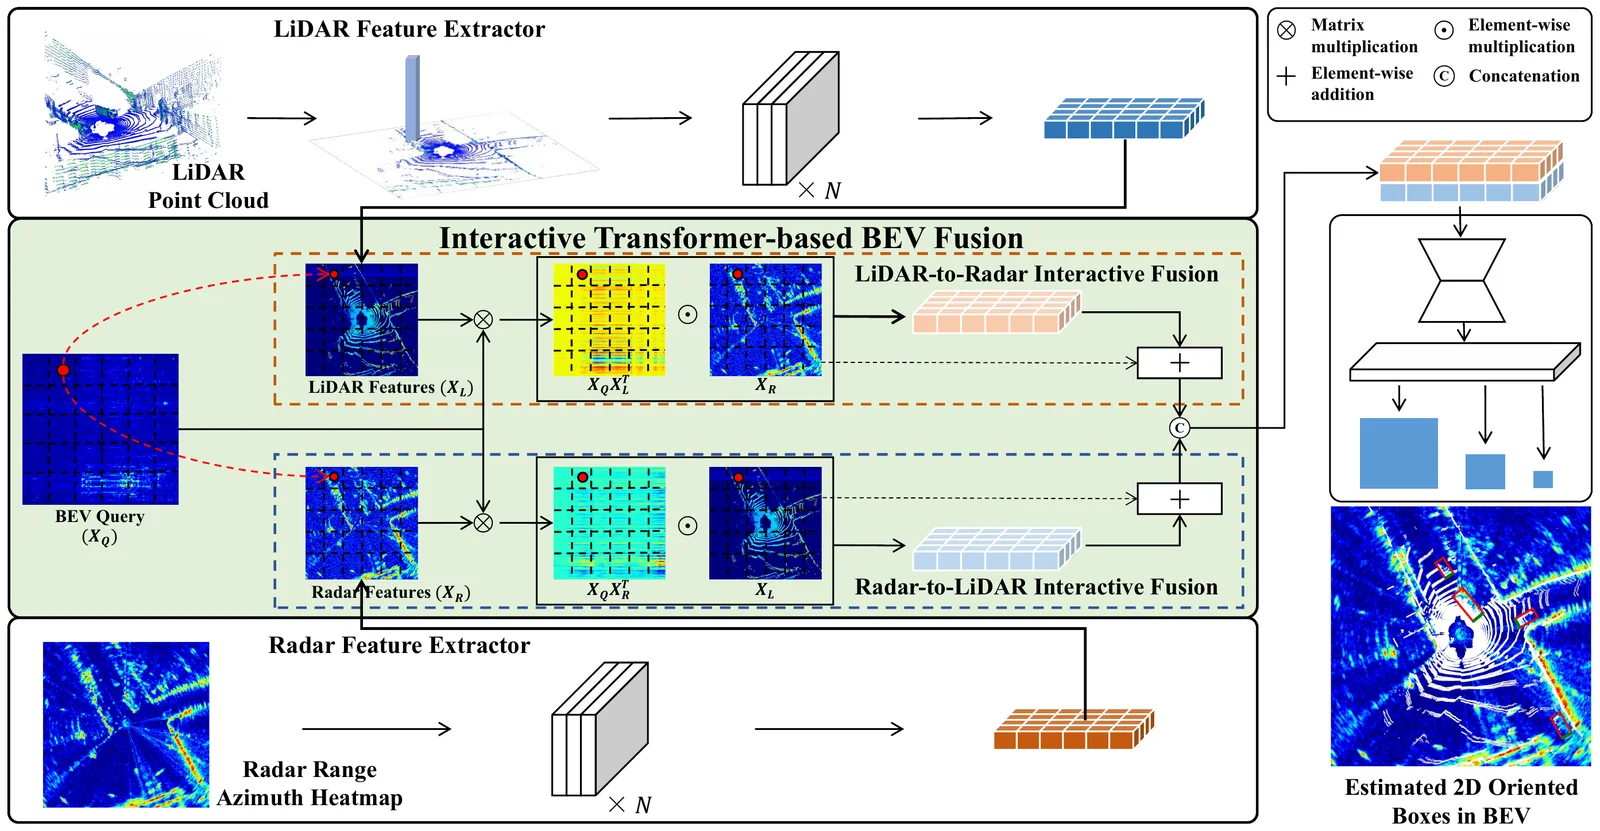
Radar penetrates rain and fog where LiDAR degrades. RaLiBEV fuses radar range–azimuth heatmaps with LiDAR point clouds in a bird's-eye-view representation, using an interactive transformer-based fusion module and a consistency-aware label assignment strategy for anchor-box-free detection.
It outperforms prior methods by 13.1% in clear weather and 19.0% in fog at IoU 0.8.
Highlights
- Interactive transformer fusion of radar and LiDAR
- Consistency-aware label assignment, anchor-box-free
- +19.0% in fog at IoU 0.8
Publication
★RaLiBEV: Radar and LiDAR BEV Fusion Learning for Anchor-Box-Free Object Detection Systems
Y. Yang*, J. Liu*, T. Huang, Q.-L. Han, G. Ma, B. Zhu
IEEE Transactions on Circuits and Systems for Video Technology · 35(5):4130–4143 · *equal contribution
Fuses radar range–azimuth heatmaps with LiDAR in bird's-eye view for all-weather detection: +13.1% (clear) and +19.0% (fog) at IoU 0.8.
IEEEarXivCodeProject