RadarINV — Unsupervised Radar Point-Cloud Enhancement
First author · arXiv 2025
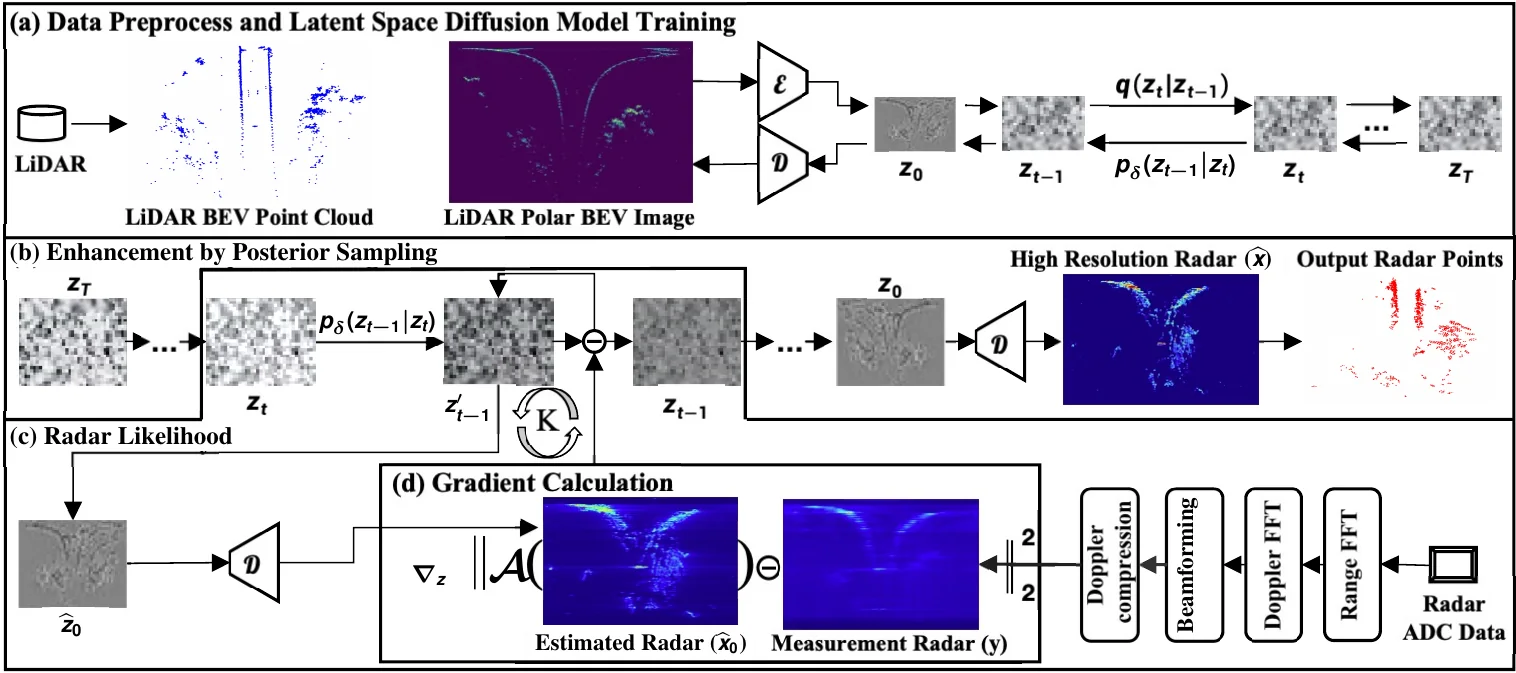
A small automotive radar array cannot resolve nearby targets in angle, so its point clouds are sparse and noisy. RadarINV enhances them toward LiDAR-like density using a diffusion prior learned from arbitrary, unpaired LiDAR data — removing the need for paired radar/LiDAR supervision.
The project began at Vanjee as radar super-resolution from raw radar signals and continued into my PhD.
Highlights
- Unsupervised: no paired radar/LiDAR data
- Diffusion prior from arbitrary LiDAR datasets
- Array super-resolution as an inverse problem
Publication
★Unsupervised Radar Point-Cloud Enhancement via Arbitrary LiDAR-Guided Diffusion Prior
Y. Yang, J. Liu, G. Luo, H. Li, E. Ahn, M. Rahimi Azghadi, T. Huang
arXiv:2505.09887
Enhances sparse, noisy radar point clouds toward LiDAR-like density with a diffusion prior learned from arbitrary, unpaired LiDAR data.
arXivCodeProject